Loading...
Searching...
No Matches
frame_visibility.hpp File Reference
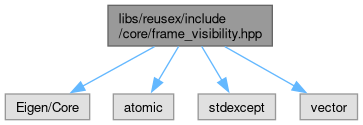
#include <Eigen/Core>#include <atomic>#include <stdexcept>#include <vector>
Include dependency graph for frame_visibility.hpp:
Go to the source code of this file.
Classes | |
| struct | reusex::core::FrameVisibility |
| One frame in which a queried world point is visible, with the geometry of its projection. More... | |
| struct | reusex::core::VisibilityQuery |
| Tunables for visible_frames(). More... | |
| struct | reusex::core::OcclusionQuery |
| Tunables for visible_frames_occluded(). More... | |
| struct | reusex::core::VisibilityProbe |
| What visible_frames_occluded() tests for one object: an anchor that decides the frustum test and the ranking (usually the centroid), plus surface samples. More... | |
| class | reusex::core::OperationCancelled |
| Thrown by visible_frames_occluded() when its cancel flag is raised. More... | |
Namespaces | |
| namespace | reusex |
| namespace | reusex::core |
| Wire form of one stored report PDF version — the ReportPdfVersion schema in ruxd's API contract (docs/gui/openapi.yaml, in the ruxd repo). | |
Functions | |
| std::vector< FrameVisibility > | reusex::core::visible_frames (const ProjectDB &db, const Eigen::Vector3d &world_point, const VisibilityQuery &query={}) |
| Rank the posed sensor frames by how centrally a world point projects. | |
| std::vector< std::vector< FrameVisibility > > | reusex::core::visible_frames_batch (const ProjectDB &db, const std::vector< Eigen::Vector3d > &world_points, const VisibilityQuery &query={}) |
| visible_frames() for many points at once. | |
| std::vector< std::vector< FrameVisibility > > | reusex::core::visible_frames_occluded (const ProjectDB &db, const std::vector< VisibilityProbe > &probes, const OcclusionQuery &query={}, const std::atomic< bool > *cancel=nullptr) |
| Occlusion-aware visible_frames_batch(): frames that actually see each probe, not merely frames whose frustum contains it. | |
