Loading...
Searching...
No Matches
glass_filter.hpp File Reference
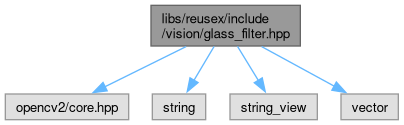
#include <opencv2/core.hpp>#include <string>#include <string_view>#include <vector>
Include dependency graph for glass_filter.hpp:
Go to the source code of this file.
Namespaces | |
| namespace | reusex |
| namespace | reusex::vision |
Functions | |
| const std::vector< std::string > & | reusex::vision::glass_prompt_list () |
| Returns the canonical list of glass/mirror/transparent-surface prompt strings used by the glass depth filter. | |
| bool | reusex::vision::is_glass_class (std::string_view class_name) |
| Returns true when class_name matches one of the glass prompt strings. | |
| cv::Mat | reusex::vision::build_glass_confidence_map (const cv::Mat &label_image, const std::vector< int > &glass_ids) |
| Build a per-frame binary glass confidence map from a semantic label image. | |
| std::string | reusex::vision::find_duplicate_prompt_concept (const std::vector< std::string > &prompts) |
Returns the first duplicate concept text found in prompts after stripping optional :threshold suffixes, or an empty string if the list is duplicate-free. | |
