Loading...
Searching...
No Matches
instance_crop.hpp File Reference
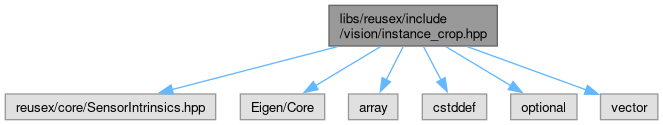
#include "reusex/core/SensorIntrinsics.hpp"#include <Eigen/Core>#include <array>#include <cstddef>#include <optional>#include <vector>
Include dependency graph for instance_crop.hpp:
Go to the source code of this file.
Classes | |
| struct | reusex::vision::ProjectedBox |
| A projected 2D bounding box of an instance in one frame, with the count of points that landed inside the image. More... | |
Namespaces | |
| namespace | reusex |
| namespace | reusex::vision |
Functions | |
| std::optional< ProjectedBox > | reusex::vision::project_points_to_box (const std::vector< Eigen::Vector3f > &world_points, const std::array< double, 16 > &pose, const core::SensorIntrinsics &intrinsics, int image_width, int image_height) |
Project world_points into the camera described by pose (row-major 4x4 base-to-world) and intrinsics, returning the pixel bounding box of the points that fall in front of the camera AND inside the image. | |
