Loading...
Searching...
No Matches
mask_selection.hpp File Reference
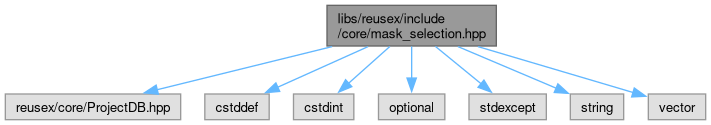
#include "reusex/core/ProjectDB.hpp"#include <cstddef>#include <cstdint>#include <optional>#include <stdexcept>#include <string>#include <vector>
Include dependency graph for mask_selection.hpp:
Go to the source code of this file.
Classes | |
| class | reusex::core::MaskSelectionError |
| A frame cannot be projected (no usable pose, no depth image, no base cloud, degenerate intrinsics) or a selection is unusable (no points). More... | |
| struct | reusex::core::MaskProjectionOptions |
| Tunables for project_frame_mask() (STANDARDS §4). More... | |
| struct | reusex::core::MaskSelectionOptions |
| Tunables for apply_mask_selection(). More... | |
| struct | reusex::core::MaskSelectionResult |
| What apply_mask_selection() created. More... | |
Namespaces | |
| namespace | cv |
| Turn a 2D mask drawn on one sensor frame into a labelled 3D selection and a survey part (Segmentering view, spec B2). | |
| namespace | reusex |
| namespace | reusex::core |
| Wire form of one stored report PDF version — the ReportPdfVersion schema in ruxd's API contract (docs/gui/openapi.yaml, in the ruxd repo). | |
Functions | |
| std::vector< std::size_t > | reusex::core::project_frame_mask (const ProjectDB &db, int frame_id, const cv::Mat &mask, const MaskProjectionOptions &opts={}) |
| Indices of the base-cloud points that the mask covers in one frame. | |
| MaskSelectionResult | reusex::core::apply_mask_selection (ProjectDB &db, const std::vector< std::size_t > &indices, const std::string &class_name, const MaskSelectionOptions &opts={}) |
| Label the selected points as class_name, make them one new instance, and file a survey part for it — in one transaction. | |
