Loading...
Searching...
No Matches
sam3_geometry.hpp File Reference
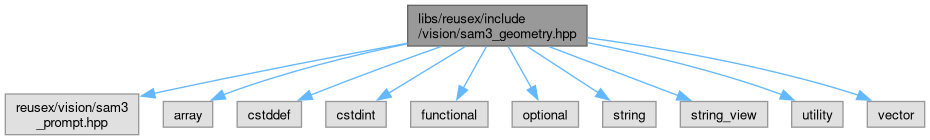
#include "reusex/vision/sam3_prompt.hpp"#include <array>#include <cstddef>#include <cstdint>#include <functional>#include <optional>#include <string>#include <string_view>#include <utility>#include <vector>
Include dependency graph for sam3_geometry.hpp:
Go to the source code of this file.
Classes | |
| class | reusex::vision::Sam3GeometryFailures |
| When a request's geometry path fails at run time (encode_boxes / decode with a geometry slot), the request is re-run text-only. More... | |
Namespaces | |
| namespace | reusex |
| namespace | reusex::vision |
Functions | |
| std::array< float, 4 > | reusex::vision::sam3_box_cxcywh (const std::array< float, 4 > &xyxy, int image_w, int image_h) |
Pixel box [x1, y1, x2, y2] (corners in any order) -> the normalised [cx, cy, w, h] the SAM3 geometry encoder takes, clamped to the image_w x image_h image. | |
| std::int64_t | reusex::vision::sam3_box_label (std::string_view polarity) noexcept |
| SAM3 box label: 1 for a positive ("pos") box, 0 for a negative one. | |
| int | reusex::vision::sam3_geometry_slot_len (int max_boxes) noexcept |
Geometry tokens one prompt slot holds when the largest prompt in a decoder batch has max_boxes boxes: the geometry encoder emits one token per box plus a CLS token, so max_boxes + 1, or 0 when no prompt has a box. | |
| std::vector< std::uint8_t > | reusex::vision::sam3_geometry_slot_mask (int n_boxes, int slot_len) |
Validity of one prompt's geometry slot of slot_len tokens holding n_boxes encoded boxes: 1 == a token the decoder attends to, 0 == padding. | |
| std::optional< bool > | reusex::vision::sam3_mask_true_is_valid (const std::vector< std::uint8_t > &mask, int real_tokens) |
Which way an export's bool token masks point, read off the text encoder's own output for an input whose first real_tokens tokens are real and the rest padding. | |
| constexpr bool | reusex::vision::sam3_mask_value (bool valid, bool true_is_valid) noexcept |
The bool an engine mask holds for a token that is valid, under the polarity sam3_mask_true_is_valid() found. | |
| int | reusex::vision::sam3_geometry_box_count (std::size_t requested, int capacity) noexcept |
Boxes actually fed for a prompt with requested boxes when the model accepts at most capacity (0 = geometry disabled). | |
| int | reusex::vision::sam3_geometry_capacity (int model_cap, int encoder_min_boxes, int encoder_max_boxes, int text_len, int decoder_max_len) noexcept |
| Most boxes per prompt the engines can take, or 0 when geometry prompting is unusable. | |
| bool | reusex::vision::sam3_detection_selected (const std::array< float, 4 > &det_xyxy, const std::vector< SegmentBox > &boxes, const std::vector< std::array< float, 2 > > &points={}, const std::function< bool(float, float)> &covers={}) |
Does a detection with pixel box det_xyxy belong to a box-prompted selection? | |
| const std::vector< float > & | reusex::vision::sam3_point_exemplar_fracs () |
| Exemplar box half-sizes, as fractions of the image's shorter side, a click point is tried at. | |
| std::array< float, 4 > | reusex::vision::sam3_point_exemplar_box (const std::array< float, 2 > &point, int image_w, int image_h, float frac) |
The exemplar box [x1, y1, x2, y2] for a click point: half-size frac of the image's shorter side, clamped to the image. | |
| std::vector< std::size_t > | reusex::vision::sam3_best_detection_per_point (const std::vector< float > &scores, const std::vector< std::vector< bool > > &covers) |
Which detections a click selects: for each point, the single highest- scoring detection that covers it (covers[d][p]: detection d covers point p). | |
| std::vector< std::size_t > | reusex::vision::sam3_point_prompt_selection (const std::vector< float > &scores, const std::vector< std::vector< bool > > &covers, const std::vector< bool > &box_selected) |
| The detections a prompt with click points keeps: the UNION of. | |
