Loading...
Searching...
No Matches
reusex::core::PhotoQuery Struct Reference
Tunables for the photo evidence of an instance. More...
#include <instance_evidence.hpp>
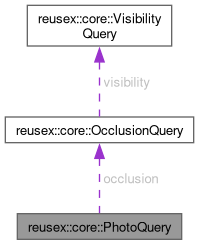
Collaboration diagram for reusex::core::PhotoQuery:
Public Attributes | |
| OcclusionQuery | occlusion {} |
| How a frame decides it sees the instance (depth tolerance etc.). | |
| std::size_t | samples_per_instance = 8 |
| Surface points per instance tested besides the centroid (spread evenly over the instance's points). | |
Detailed Description
Tunables for the photo evidence of an instance.
Definition at line 67 of file instance_evidence.hpp.
Member Data Documentation
◆ occlusion
| OcclusionQuery reusex::core::PhotoQuery::occlusion {} |
How a frame decides it sees the instance (depth tolerance etc.).
Definition at line 69 of file instance_evidence.hpp.
◆ samples_per_instance
| std::size_t reusex::core::PhotoQuery::samples_per_instance = 8 |
Surface points per instance tested besides the centroid (spread evenly over the instance's points).
The centroid of a door frame or a chair is in the air; these are what let the depth test find it. 0 tests the centroid alone.
Definition at line 74 of file instance_evidence.hpp.
The documentation for this struct was generated from the following file:
- libs/reusex/include/core/instance_evidence.hpp
