Loading...
Searching...
No Matches
reusex::io::ImportPanoramasOptions Struct Reference
Controls auto-discovery and import of companion 360° panoramas. More...
#include <panoramas.hpp>
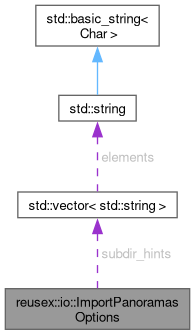
Collaboration diagram for reusex::io::ImportPanoramasOptions:
Public Attributes | |
| bool | skip = false |
| When true, skip panorama discovery entirely (–no-panoramas CLI flag). | |
| std::vector< std::string > | subdir_hints = {"360", "panoramas", "pano"} |
| Subdirectory names searched first for companion panoramas. | |
| bool | stitch_insp = true |
| When true (default), stitch .insp dual-fisheye files using the static Insta360 X4 calibration (see io/insta360_x4.hpp). | |
Detailed Description
Controls auto-discovery and import of companion 360° panoramas.
Definition at line 18 of file panoramas.hpp.
Member Data Documentation
◆ skip
| bool reusex::io::ImportPanoramasOptions::skip = false |
When true, skip panorama discovery entirely (–no-panoramas CLI flag).
Definition at line 20 of file panoramas.hpp.
◆ stitch_insp
| bool reusex::io::ImportPanoramasOptions::stitch_insp = true |
When true (default), stitch .insp dual-fisheye files using the static Insta360 X4 calibration (see io/insta360_x4.hpp).
Set to false to skip .insp files entirely (e.g. if stitch quality needs manual verification before import, or for benchmarking without stitching overhead).
Definition at line 32 of file panoramas.hpp.
◆ subdir_hints
| std::vector<std::string> reusex::io::ImportPanoramasOptions::subdir_hints = {"360", "panoramas", "pano"} |
Subdirectory names searched first for companion panoramas.
If any of these directories exist under the capture root, only those directories are scanned (non-recursively). If none exist, the root directory itself is scanned one level deep as a fallback.
Definition at line 26 of file panoramas.hpp.
The documentation for this struct was generated from the following file:
- libs/reusex/include/io/panoramas.hpp
