Loading...
Searching...
No Matches
reusex::vision::Sam3Prompt Struct Reference
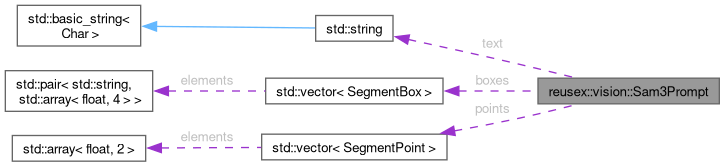
One SAM3 prompt: text class name plus optional positive/negative bounding boxes and positive click points. More...
#include <sam3_prompt.hpp>
Collaboration diagram for reusex::vision::Sam3Prompt:
Public Member Functions | |
| Sam3Prompt (std::string t, std::vector< SegmentBox > b={}, float conf=-1.0f) | |
Public Attributes | |
| std::string | text |
| std::vector< SegmentBox > | boxes |
| std::vector< SegmentPoint > | points |
| Positive click points. | |
| float | confidence = -1.0f |
| Per-prompt confidence override. Negative ⟹ use the global threshold. | |
Detailed Description
One SAM3 prompt: text class name plus optional positive/negative bounding boxes and positive click points.
Definition at line 47 of file sam3_prompt.hpp.
Constructor & Destructor Documentation
◆ Sam3Prompt()
|
inlineexplicit |
Definition at line 58 of file sam3_prompt.hpp.
Member Data Documentation
◆ boxes
| std::vector<SegmentBox> reusex::vision::Sam3Prompt::boxes |
Definition at line 49 of file sam3_prompt.hpp.
◆ confidence
| float reusex::vision::Sam3Prompt::confidence = -1.0f |
Per-prompt confidence override. Negative ⟹ use the global threshold.
Definition at line 56 of file sam3_prompt.hpp.
◆ points
| std::vector<SegmentPoint> reusex::vision::Sam3Prompt::points |
Positive click points.
SAM3's exported detector takes boxes only, so a backend with a geometry encoder feeds each point as a small exemplar box (sam3_point_exemplar_box) and keeps the detections whose mask covers a point; a backend without one clips the prompt's pixels to that box.
Definition at line 54 of file sam3_prompt.hpp.
◆ text
| std::string reusex::vision::Sam3Prompt::text |
Definition at line 48 of file sam3_prompt.hpp.
The documentation for this struct was generated from the following file:
- libs/reusex/include/vision/sam3_prompt.hpp
