Loading...
Searching...
No Matches
reusex::vision::sam3::EngineProfile Struct Reference
Per-engine TensorRT build recipe, deserialized from engine-build.json. More...
#include <EngineBuildProfiles.hpp>
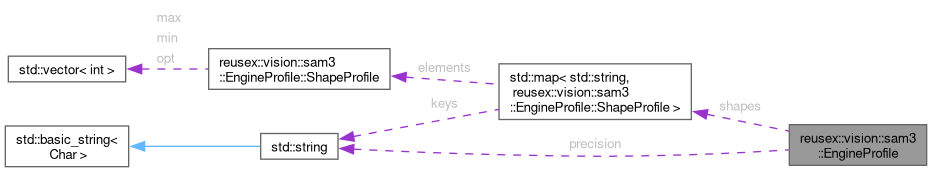
Collaboration diagram for reusex::vision::sam3::EngineProfile:
Classes | |
| struct | ShapeProfile |
| Min / opt / max dimensions for one dynamic (or static) input tensor. More... | |
Public Member Functions | |
| bool | operator== (const EngineProfile &) const =default |
| bool | is_fp16 () const |
| bool | is_fp32 () const |
Public Attributes | |
| std::string | precision = "fp16" |
| "fp16" or "fp32". | |
| int | workspace_mb = 8192 |
| trtexec / IBuilderConfig workspace memory pool, in MiB. | |
| std::map< std::string, ShapeProfile > | shapes |
| Optimization-profile shapes, keyed by input tensor name. | |
Detailed Description
Per-engine TensorRT build recipe, deserialized from engine-build.json.
engine-build.json is the SINGLE SOURCE OF TRUTH for how each SAM 3.1 ONNX graph is turned into a TensorRT engine. It is emitted by the Python export pipeline (python/reusex_sam3/build_engines.py) and shipped in the model bundle next to the *.onnx files. Both the Python trtexec driver and the native C++ EngineBuilder read it, so the two can never drift.
The recipe here is already fully resolved — the fp32-vision-encoder rule and its batch-1/workspace overrides (see build_engines.py FP32_ENGINES / FP32_SHAPE_OVERRIDES / FP32_WORKSPACE_MB) are baked into precision, shapes and workspace_mb by the emitter, so the consumer applies the values verbatim with no special cases.
This header is backend-agnostic (no NvInfer include), so it compiles in CPU-only builds; the NvInfer-dependent consumer lives in vision/tensor_rt/common/EngineBuilder.hpp.
Definition at line 33 of file EngineBuildProfiles.hpp.
Member Function Documentation
◆ is_fp16()
|
inlinenodiscard |
Definition at line 56 of file EngineBuildProfiles.hpp.
References precision.
◆ is_fp32()
|
inlinenodiscard |
Definition at line 57 of file EngineBuildProfiles.hpp.
References precision.
◆ operator==()
|
default |
Member Data Documentation
◆ precision
| std::string reusex::vision::sam3::EngineProfile::precision = "fp16" |
"fp16" or "fp32".
The bf16-native vision-encoder MUST be "fp32": fp16 silently corrupts its ViT-L trunk into all-background output.
Definition at line 45 of file EngineBuildProfiles.hpp.
◆ shapes
| std::map<std::string, ShapeProfile> reusex::vision::sam3::EngineProfile::shapes |
Optimization-profile shapes, keyed by input tensor name.
Empty for a fully static engine.
Definition at line 52 of file EngineBuildProfiles.hpp.
◆ workspace_mb
| int reusex::vision::sam3::EngineProfile::workspace_mb = 8192 |
trtexec / IBuilderConfig workspace memory pool, in MiB.
Definition at line 48 of file EngineBuildProfiles.hpp.
The documentation for this struct was generated from the following file:
- libs/reusex/include/vision/sam3/EngineBuildProfiles.hpp
