Loading...
Searching...
No Matches
sam3_prompt.hpp File Reference
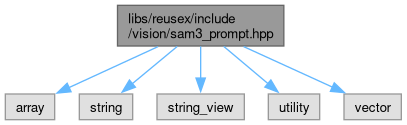
#include <array>#include <string>#include <string_view>#include <utility>#include <vector>
Include dependency graph for sam3_prompt.hpp:
Go to the source code of this file.
Classes | |
| struct | reusex::vision::Sam3Prompt |
| One SAM3 prompt: text class name plus optional positive/negative bounding boxes and positive click points. More... | |
Namespaces | |
| namespace | reusex |
| namespace | reusex::vision |
Typedefs | |
| using | reusex::vision::SegmentBox = std::pair<std::string, std::array<float, 4>> |
| A bounding-box prompt: label ("pos" or "neg") and pixel coords [x1,y1,x2,y2]. | |
| using | reusex::vision::SegmentPoint = std::array<float, 2> |
| A click-point prompt: pixel [x, y]. | |
Functions | |
| int | reusex::vision::sam3_label_value (bool by_prompt_index, int prompt_index, int cache_id) noexcept |
| The value a backend writes into the label map for one prompt's detections. | |
Variables | |
| constexpr std::string_view | reusex::vision::kGeometryOnlyPromptText = "visual" |
| Text sent to SAM3 for a prompt that carries boxes but no class name. | |
