Loading...
Searching...
No Matches
reusex::core::InstanceEvidence Struct Reference
Everything the photo evidence knows about one instance: where it is and the frames that see it, best first (visible_frames_occluded). More...
#include <instance_evidence.hpp>
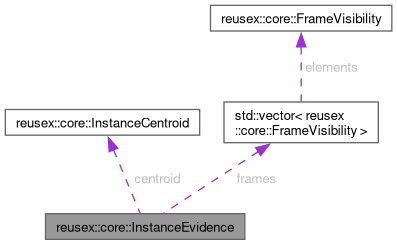
Collaboration diagram for reusex::core::InstanceEvidence:
Public Member Functions | |
| PartPhotos | photos () const |
Public Attributes | |
| InstanceCentroid | centroid |
| std::vector< FrameVisibility > | frames |
Detailed Description
Everything the photo evidence knows about one instance: where it is and the frames that see it, best first (visible_frames_occluded).
Definition at line 106 of file instance_evidence.hpp.
Member Function Documentation
◆ photos()
|
inlinenodiscard |
Definition at line 109 of file instance_evidence.hpp.
References reusex::core::PartPhotos::best_frame_id, reusex::core::PartPhotos::count, and frames.
Member Data Documentation
◆ centroid
| InstanceCentroid reusex::core::InstanceEvidence::centroid |
Definition at line 107 of file instance_evidence.hpp.
◆ frames
| std::vector<FrameVisibility> reusex::core::InstanceEvidence::frames |
Definition at line 108 of file instance_evidence.hpp.
Referenced by photos().
The documentation for this struct was generated from the following file:
- libs/reusex/include/core/instance_evidence.hpp
