Loading...
Searching...
No Matches
reusex::visualize::SceneInfo Struct Reference
What populate_scene() added. More...
#include <scene.hpp>
Collaboration diagram for reusex::visualize::SceneInfo:
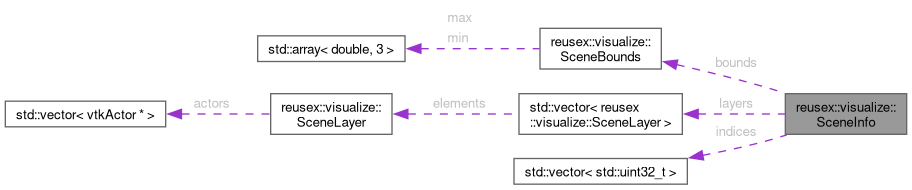
Public Attributes | |
| SceneBounds | bounds |
| std::size_t | drawn_points = 0 |
| std::size_t | drawn_faces = 0 |
| std::vector< SceneLayer > | layers |
| std::size_t | source_points = 0 |
| Points in the geometry cloud (0 when no point layer was drawn). | |
| LodMethod | lod = LodMethod::all |
| std::vector< std::uint32_t > | indices |
| Storage index of each point a full point actor draws (its vtk point id -> cloud index); empty when every point is drawn (the identity). | |
Detailed Description
What populate_scene() added.
Member Data Documentation
◆ bounds
| SceneBounds reusex::visualize::SceneInfo::bounds |
◆ drawn_faces
◆ drawn_points
| std::size_t reusex::visualize::SceneInfo::drawn_points = 0 |
◆ indices
| std::vector<std::uint32_t> reusex::visualize::SceneInfo::indices |
◆ layers
| std::vector<SceneLayer> reusex::visualize::SceneInfo::layers |
◆ lod
| LodMethod reusex::visualize::SceneInfo::lod = LodMethod::all |
◆ source_points
| std::size_t reusex::visualize::SceneInfo::source_points = 0 |
The documentation for this struct was generated from the following file:
- libs/reusex/include/visualize/scene.hpp
