Loading...
Searching...
No Matches
instance_evidence.hpp File Reference
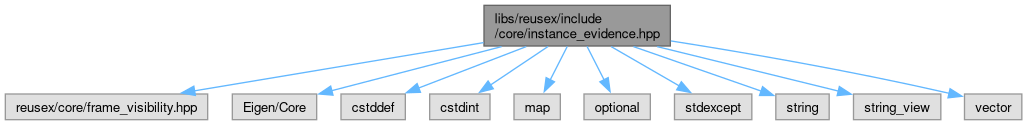
#include "reusex/core/frame_visibility.hpp"#include <Eigen/Core>#include <cstddef>#include <cstdint>#include <map>#include <optional>#include <stdexcept>#include <string>#include <string_view>#include <vector>
Include dependency graph for instance_evidence.hpp:
Go to the source code of this file.
Classes | |
| class | reusex::core::CloudMisalignedError |
| Mean position of one instance's points. More... | |
| struct | reusex::core::InstanceCentroid |
| struct | reusex::core::PhotoQuery |
| Tunables for the photo evidence of an instance. More... | |
| struct | reusex::core::InstanceProbe |
| An instance's centroid plus evenly spread samples of its points. More... | |
| struct | reusex::core::PartPhotos |
| The photo evidence of one survey part. More... | |
| struct | reusex::core::InstanceEvidence |
| Everything the photo evidence knows about one instance: where it is and the frames that see it, best first (visible_frames_occluded). More... | |
| struct | reusex::core::PanoramaQuery |
| Tunables for panoramas_for_point(). More... | |
| struct | reusex::core::PanoramaSighting |
| One panorama near a world point. More... | |
Namespaces | |
| namespace | reusex |
| namespace | reusex::core |
| Wire form of one stored report PDF version — the ReportPdfVersion schema in ruxd's API contract (docs/gui/openapi.yaml, in the ruxd repo). | |
Enumerations | |
| enum class | reusex::core::PanoramaHeading { reusex::core::resected , reusex::core::levelled } |
| Where a panorama's orientation comes from (mirrors the frontend's PanoramaHeading in viewport/panorama.ts). More... | |
Functions | |
| std::map< std::uint32_t, InstanceCentroid > | reusex::core::instance_centroids (const ProjectDB &db, std::string_view label_cloud, std::string_view positions_cloud="cloud") |
| Centroid of every instance id in an instance-label cloud. | |
| std::map< std::uint32_t, InstanceProbe > | reusex::core::instance_probes (const ProjectDB &db, std::string_view label_cloud, std::string_view positions_cloud="cloud", std::size_t samples=PhotoQuery{}.samples_per_instance) |
instance_centroids() plus up to samples points per instance, taken at evenly spaced positions in the instance's (finite) point list — spatially spread, since the clouds are stored in Morton order (#394). | |
| std::map< std::uint32_t, InstanceEvidence > | reusex::core::instance_evidence (const ProjectDB &db, std::string_view label_cloud, const PhotoQuery &query={}, std::string_view positions_cloud="cloud", const std::atomic< bool > *cancel=nullptr) |
The ranked, occlusion-aware frames of every instance of label_cloud that has points: visible_frames_occluded over all its probes in one pass over the frames (each depth image decoded at most once). | |
| std::map< std::uint32_t, PartPhotos > | reusex::core::instance_photos (const ProjectDB &db, std::string_view label_cloud, const PhotoQuery &query={}, std::string_view positions_cloud="cloud") |
| instance_evidence() reduced to count + best frame per instance. | |
| Eigen::Vector2d | reusex::core::equirect_uv (const Eigen::Vector3d &bearing) |
| Normalised equirect coordinates of a bearing in the panorama frame. | |
| std::vector< PanoramaSighting > | reusex::core::panoramas_for_point (const ProjectDB &db, const Eigen::Vector3d &world_point, const PanoramaQuery &query={}) |
Panoramas that can be placed in the world, nearest first, with where world_point appears in each. | |
